rFPro Scene Simulation Software
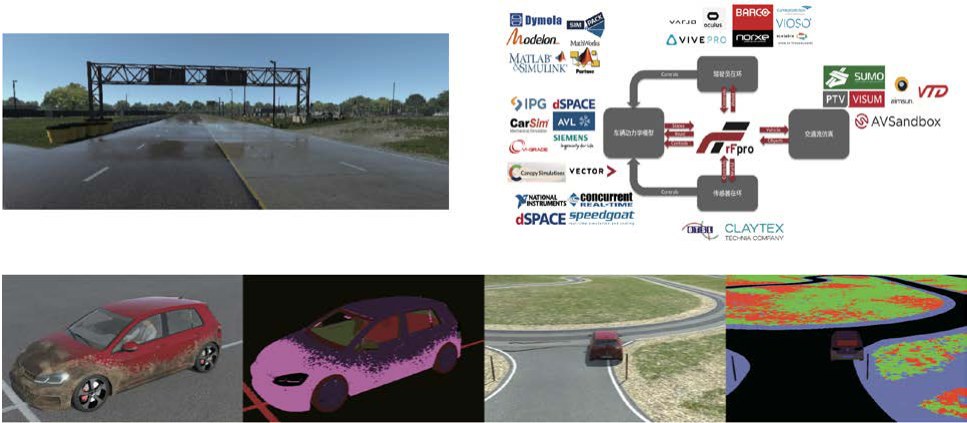
rFpro is a high-fidelity simulation environment software designed for the development and validation of autonomous driving and ADAS systems. It builds a reproducible and scalable 'ground truth' level virtual world through millimeter-level accuracy digital road models based on real LiDAR scans, together with a physically accurate ray-tracing rendering engine. rFpro accurately simulates the physical characteristics and signal outputs of sensors such as cameras, LiDAR and radar, providing support for algorithm testing, sensor fusion and V2X validation.
Its core value lies in safely, efficiently and repeatably bringing large-scale, hazardous or hard-to-reproduce real-world driving scenarios into the laboratory, thereby accelerating the R&D cycle of intelligent vehicles and supporting comprehensive functional safety validation.
Product Features
·Scenario library and efficient scenario generation: supports parametric scenarios and batch runs covering corner cases; configurable behavior models and interaction rules for other traffic participants, for complex traffic situations
·High-fidelity digital twin and sensor fidelity: builds road geometry, lane lines, signs and markings from real collected data to achieve a 'digital twin' environment consistent with real roads; performs consistent modeling of time, weather, lighting, shadow and reflection to evaluate perception robustness under different environmental conditions; supports generation of data streams close to real sensor outputs for cameras, LiDAR and millimeter-wave radar, facilitating closed-loop algorithm validation
·Closed-loop testing for autonomous driving: suitable for batch validation of typical ADAS/AD scenarios such as AEB, ACC, LKA, lane change, merge/diverge and intersections; consistent results are reproducible under the same scenario and same random seed, facilitating regression testing and issue localization; running planning/control algorithms in simulation, where vehicle behavior feeds back into scenario evolution, forms a 'perception-decision-control-environment feedback' closed-loop validation
·Unified autonomous driving development platform: supports debugging, training and testing of perception, decision, planning and control algorithms within the same platform
·High-fidelity sensor simulation: integrates high-precision sensor models such as cameras, LiDAR and millimeter-wave radar, supporting sensor fusion testing
·Synthetic training data generation: automatically generates engineering-level annotated data, improving training data production efficiency and reducing cost
·Real digital twin environment: based on real road digital twins and ray-tracing rendering, providing high-quality training and testing scenarios
·Scenario management and generalization testing: supports OpenSCENARIO and OpenDRIVE, enabling quick configuration of weather, traffic, pedestrians and edge-risk scenarios
·Closed-loop algorithm validation: supports complete closed-loop testing from virtual sensor perception to decision planning and vehicle control
·Large-scale parallel simulation: compatible with cloud HPC, enabling parallel execution of large batches of driving scenarios to validate long-term performance and stability
·HIL / SIL / DIL testing support: supports hardware-in-the-loop, software-in-the-loop and driver-in-the-loop testing, covering algorithm development to human-machine collaboration evaluation
·Sensor configuration optimization: supports parallel testing of hundreds of sensors, facilitating optimization of sensor layout and configuration schemes
·L2/L3 autonomous driving validation: suitable for L2/L3 autonomous driving function development, edge scenario testing and user experience optimization
Product Images


